UC Berkeley Engineering Design · 2025
Elbow Rehabilitation Device
Finger-driven therapy with a low-cost wearable mechanism
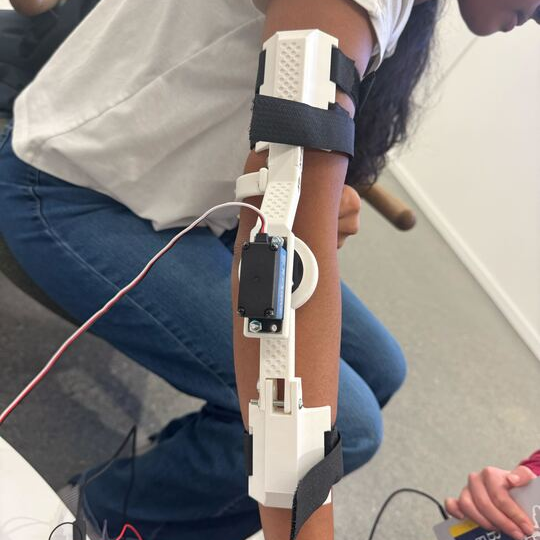
Overview
A portable rehabilitation device that converts small finger bends into powered elbow motion, with patient and therapist modes built around dual ESP32 controllers.
01
Control that feels direct
A flex sensor mounted at the finger joint gives the patient intuitive control of elbow motion without an expensive EMG setup. A second, manual mode lets a therapist guide the same mechanism with a joystick.
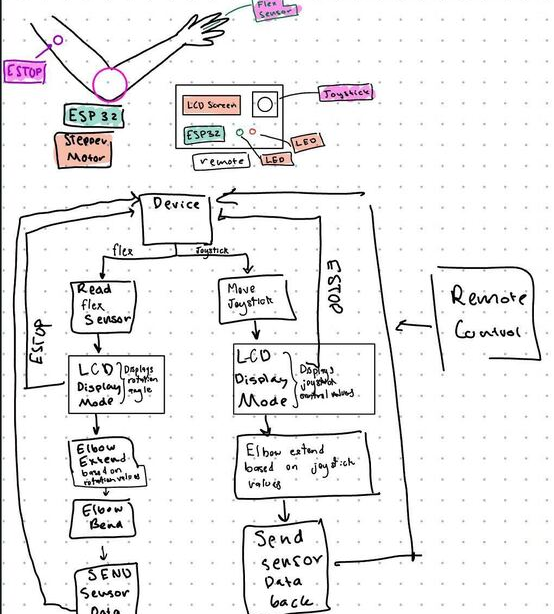
Control architecture from sensor input to elbow movement.
02
A wearable prototype, not a bench rig
The modular printed structure uses adjustable straps for fit and comfort. Signal filtering, PWM servo control, an emergency stop, LED state indicators, and an OLED display turn the mechanical concept into a usable closed-loop prototype.
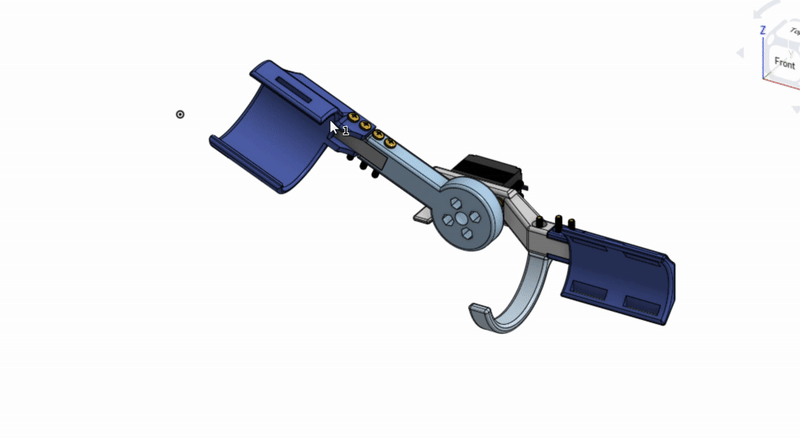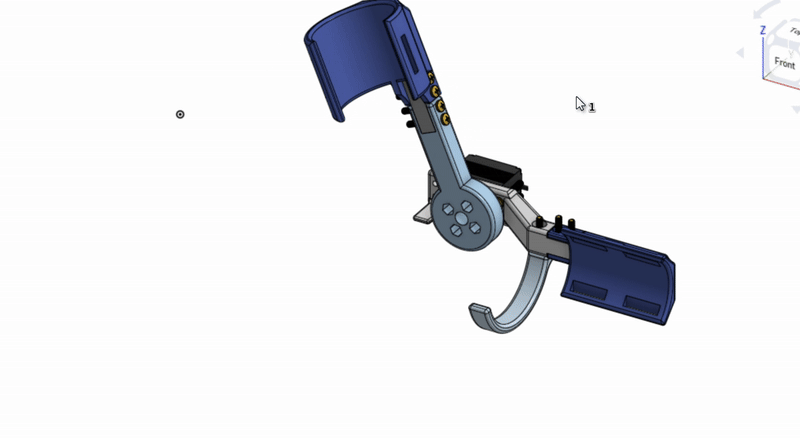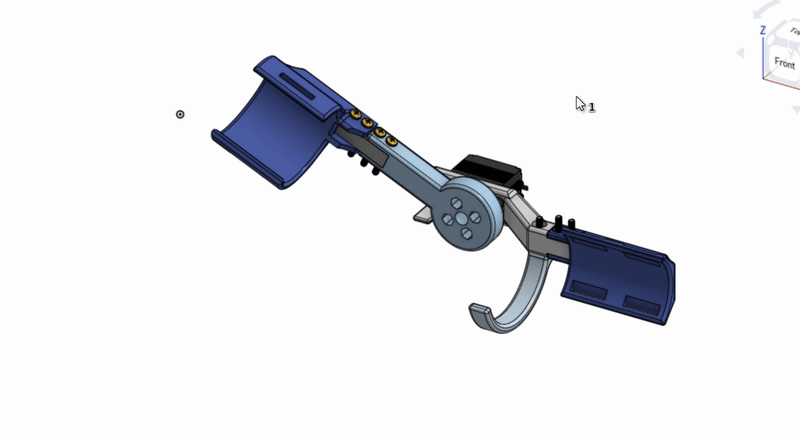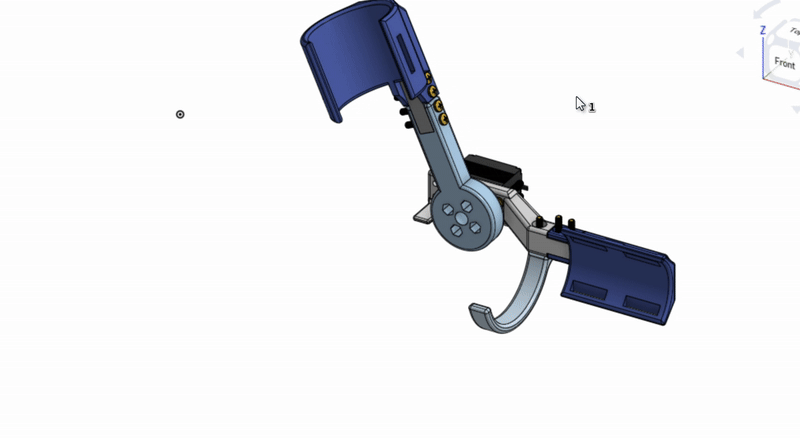
Assembled device demonstrating assisted elbow motion.
Project gallery
Tools & methods